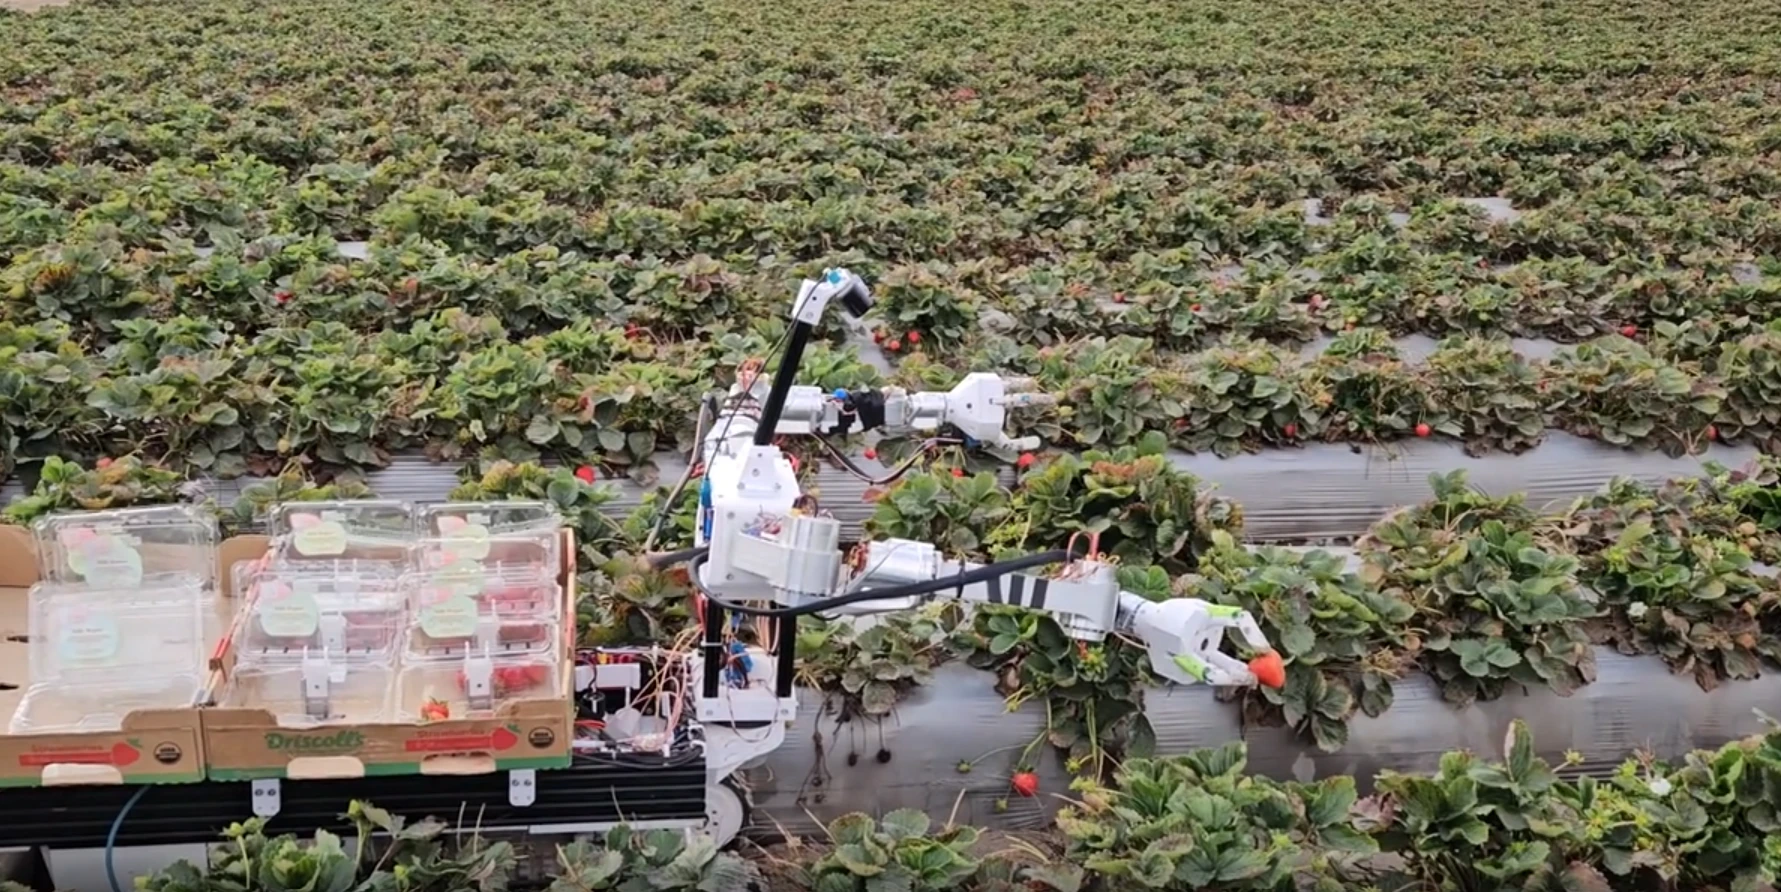
Led the mechanical design and development of a semi-humanoid robot, from concept through working prototype, applying DFM and GD&T across the platform to prepare parts and assemblies for production.
in the field with Physical Intelligence
The robot is now working in commercial fields. In October 2026, Physical Intelligence featured it in the launch of the Pi API beta: footage from a strawberry field in Salinas, CA shows it harvesting in the furrow between beds, running π foundation models fine-tuned for the task.
→ watch it in Physical Intelligence’s API announcement (select “AgRobotics”)
a note on what’s shown here
Most of the design work on this robot is under NDA, so CAD, internal photos and technical specifics aren’t shown here. This page sticks to what AgRobotics and Physical Intelligence have shown publicly. I’m happy to talk through my role and design process in more detail, within those limits.
| role | lead mechanical design: arms, torso & chassis |
| stack | Fusion 360 · DFM · GD&T · actuator & battery selection |
| seen in | Physical Intelligence: Pi API beta launch, Oct 2026 |